9:1 planetary reduction, brushless motor, 18-bit encoder and FOC driver in a Ø98 mm actuator module with CAN and RS-485 communication
Motion & Actuation · Integrated planetary actuator
RMD-X8-P9-25-C-N
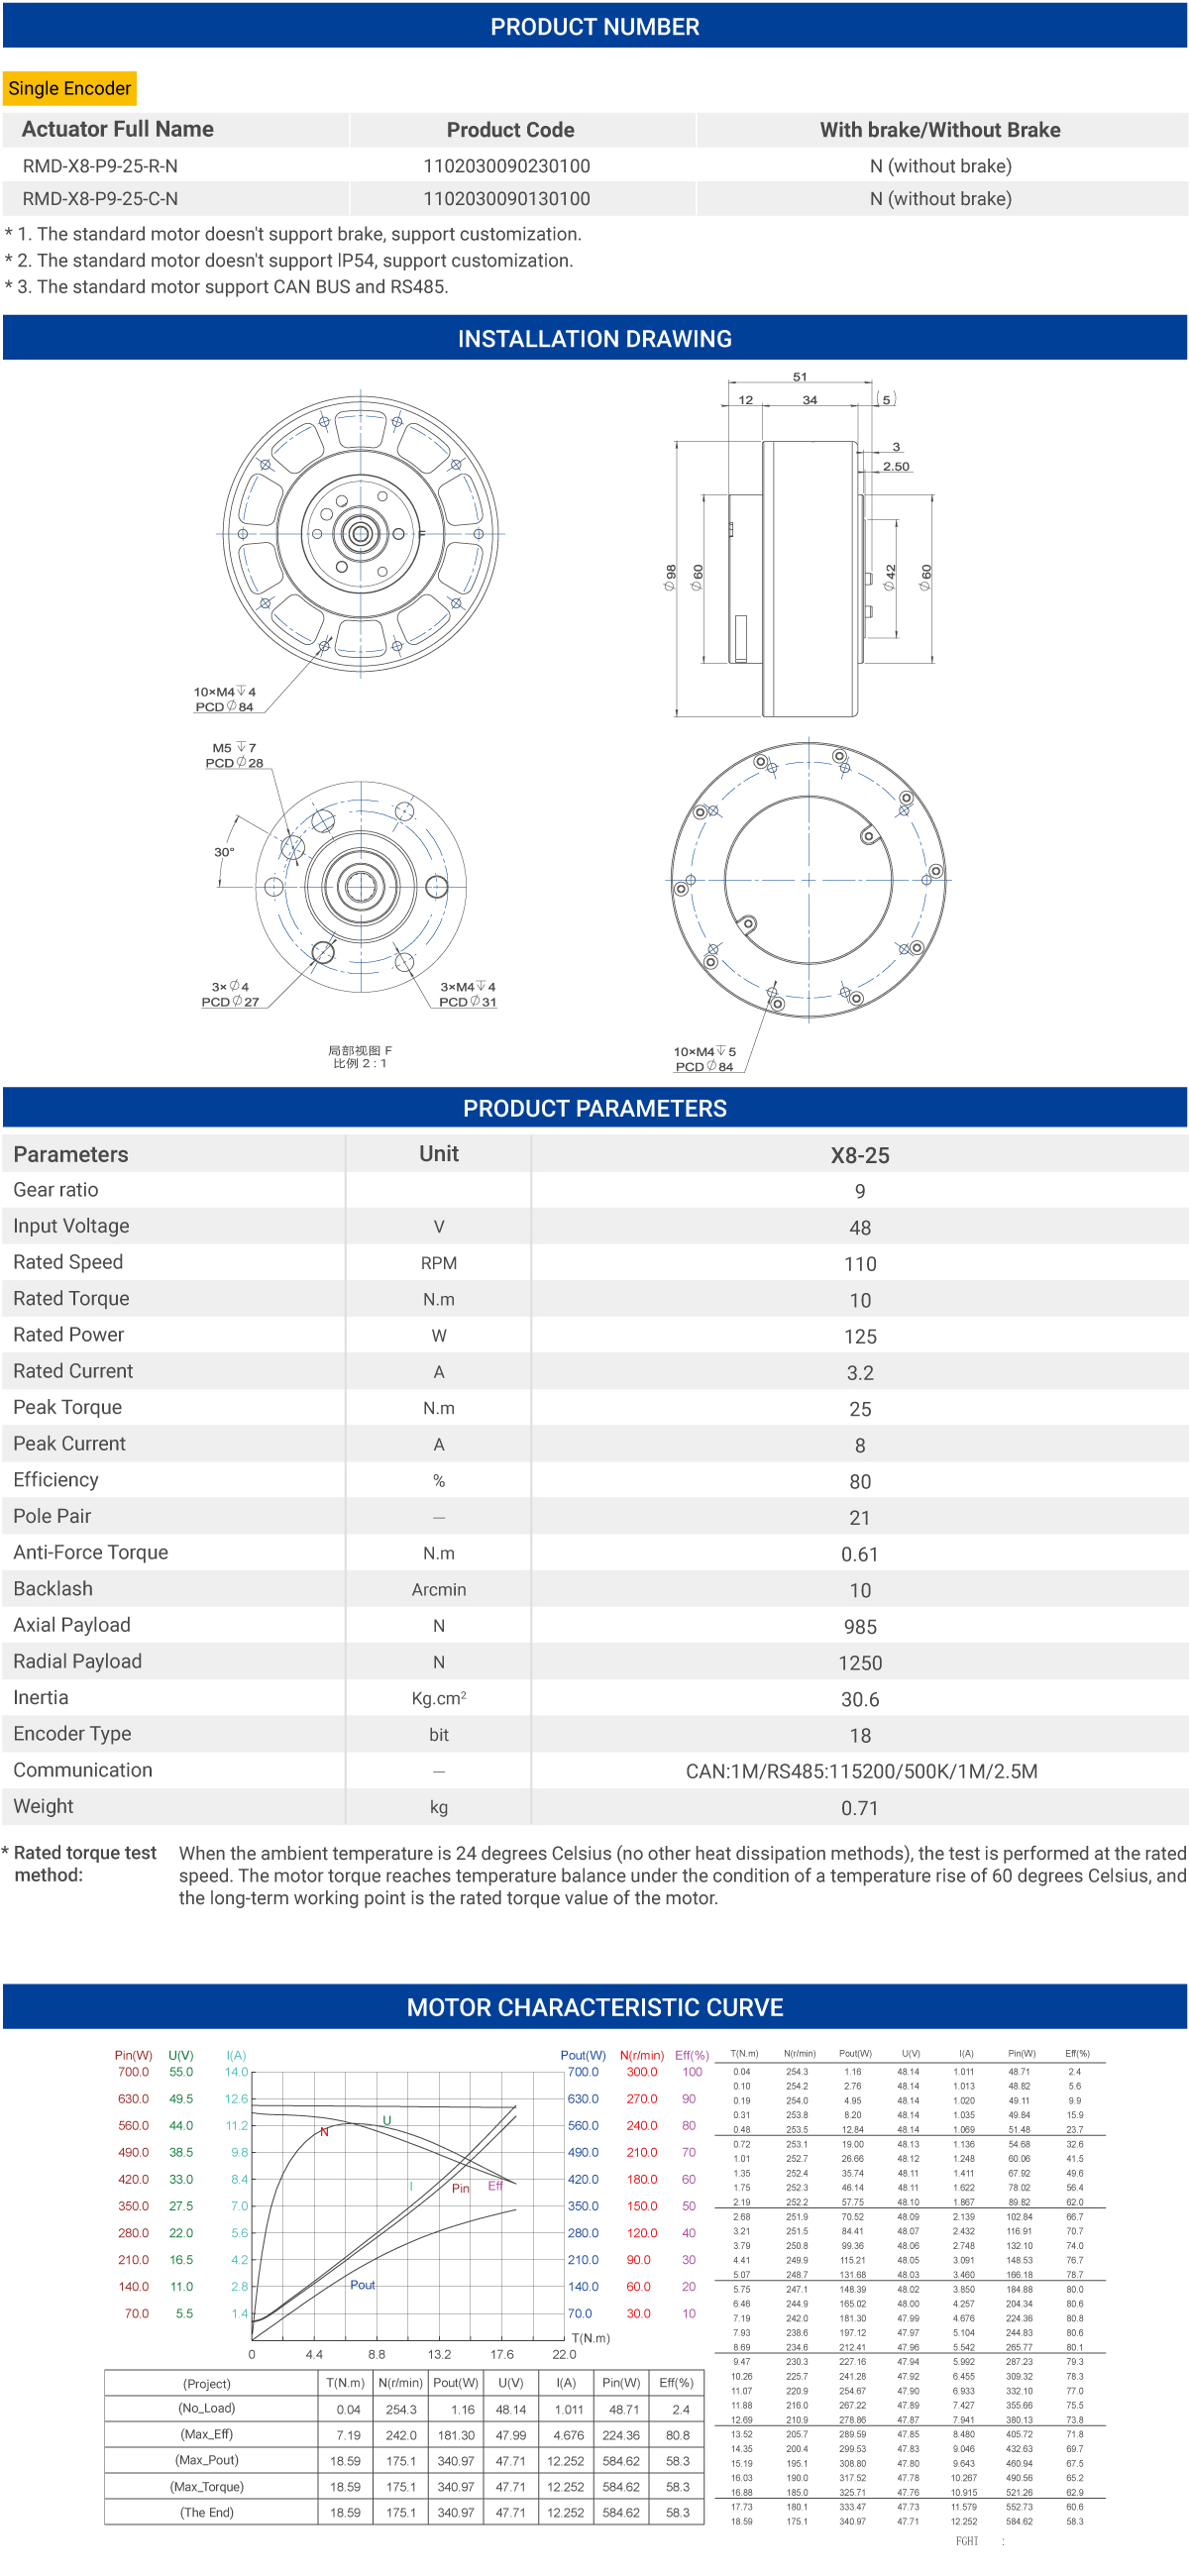
This record freezes the CAN-bus, no-brake product code RMD-X8-P9-25-C-N. The official details page states the previous name of this actuator was RMD-X8 Pro 1:9 and today lists it under the V2 single-encoder generation, not V3; the RS-485 code RMD-X8-P9-25-R-N shares the same parameter table. Unusually for this vendor, the parameter image defines the rated-torque test method as a thermal-balance long-term working point.
MYACTUATOR X8-25 V2 (previously RMD-X8 Pro 1:9) · Also: X8-25, RMD-X8-Pro 1:9, RMD-X8-P9-25-R-N (RS-485 variant)
11 known suppliers in this product family.
Motor, reduction, feedback and drive electronics sold as an integrated or near-integrated robot-joint product. The list is bounded to the current RCI manufacturer-directory universe and separates exact-model audited suppliers from confirmed product-line suppliers.
EXACT-MODEL AUDITED
8 suppliers
HEBI Robotics · ROBOTIS · CubeMars · MYACTUATOR · Unitree Robotics · mjbots · FEETECH · Damiao
PRODUCT-LINE CONFIRMED
3 suppliers
INNFOS · MAB Robotics · Synapticon
This is a bounded discovery set, not a claim to enumerate every company worldwide. Open the full supplier landscape and official routes →
What this record can support today.
Coverage is computed from published, non-unknown fields. It measures the record—not product quality—and makes missing procurement evidence explicit.
Engineering field coverage73%
8 of 11 selected fields published
- Official product sourcepublished
- Lifecycle statepublished
- Mechanical dimensions / mass / mountingpublished
- Environmental operating limitsmissing
- Continuous or rated outputpublished
- Peak / momentary outputmissing
- Speed boundarypublished
- Transmission ratio / errorpublished
- Electrical input / consumptionpublished
- Control and communication interfacemissing
- Position / torque feedbackpublished
Procurement field coverage15%
2 of 13 selected fields published
- Official product / sales routepublished
- Lifecycle statepublished
- Exact orderable SKU / part numbermissing
- Price with region, currency and quantitymissing
- Lead time with check datemissing
- Commercial availability / stock statemissing
- Minimum order quantitymissing
- Authorized distributor / sales channelmissing
- CAD / STEP / interface drawingmissing
- Certification with identifiermissing
- MTBF / failure / reliability datamissing
- Warranty termsmissing
- PCN / EOL / replacement noticemissing
Coverage measures whether a selected public field is present with non-U evidence. It is not a product score, compatibility result, certification, availability confirmation or procurement recommendation. Download the complete readiness coverage JSON →
1 bounded physical-evidence record.
Publisher independence, identity precision and measurement scope vary by row. Results remain bounded by the disclosed specimen, setup, workload and metric; an inconclusive mapping is evidence associated with the catalog model, not verification of a manufacturer claim.
| Measured result | Conditions | Claim mapping | Source |
|---|---|---|---|
| Independent real-system experimentindependent_physical_evidence | Three legacy RMD-X8 Pro actuators operated in a physical five-axis armReal-time nonlinear control experiments with load and disturbance tests. | inconclusiveThe record establishes bounded physical evidence for the named model, but the experiment does not reproduce the catalogued claim metric and conditions; the claim remains inconclusive. | Real-time Nonlinear Model Predictive Control of a Robotic Arm Using Spatial Operator Algebra Theory ↗Robot description and experimental results Checked 2026-08-26 |
Reported values, conditions attached.
Evidence state describes the claim—not the prestige of the company or document.
| Claim | Reported value | Condition / boundary | State | Source |
|---|---|---|---|---|
| Exact product codes and previous namemodel_identity | RMD-X8-P9-25-C-N (code 1102030090130100); RMD-X8-P9-25-R-N (code 1102030090230100); previous name RMD-X8-Pro 1:9 | N designates without brake; the page states the standard motor does not support a brake or IP54 and supports CAN BUS and RS485. | M · Manufacturer claimed | MYACTUATOR V2-X8-25 details page ↗Product-number table, previous-name statement and nomenclature key · Live official details page observed 2026-08-18 Checked 2026-08-19 |
| Gear ratiogear_ratio | 9 | P9 in the model name is defined by the nomenclature key as the planetary reduction ratio; the parameter table lists gear ratio 9. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Input voltageinput_voltage | 48 V | Single published value; no tolerance band is given in the parameter table. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Rated torque with published thermal test methodcontinuous_torque | 10 N·m | The table footnote defines the rated-torque test: ambient 24°C with no other heat dissipation methods, tested at rated speed, torque at temperature balance under a 60°C temperature rise, stated as “the long-term working point”.RCI carries this as the manufacturer-defined thermally balanced long-term point; it is not an RCI measurement. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Peak torqueheadline_torque | 25 N·m | Peak endpoint (peak current 8 A); the trailing 25 in the model name is defined as peak torque. Not a continuous operating point. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Rated speedspeed | 110 rpm | Rated speed at which the rated-torque thermal test is performed. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Rated power and rated currentrated_power | 125 W; 3.2 A | Parameter-table values; efficiency listed as 80%. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Weightmass | 0.71 kg | Parameter-table value. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Envelopedimensions | Ø98 × 51 mm | From the installation drawing on the parameter image; mounting interfaces are M4/M5 patterns on PCD 84/28/31. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Backlashbacklash | 10 arcmin | Parameter-table value; test method is not disclosed. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Anti-force (back-drive) torquebackdrive_torque | 0.61 N·m | Parameter-table value; test method is not disclosed. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Encoderencoder | 18-bit encoder type; single-encoder generation | The details page carries a “Single Encoder” banner for this V2 product; the table lists encoder type 18 bit. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Communicationcommunications | CAN: 1 M; RS485: 115200 / 500 K / 1 M / 2.5 M | Parameter-table row; this record freezes the CAN product code, with the RS-485 code sharing the table. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Payload and inertia figuresload_ratings | Axial payload 985 N; radial payload 1250 N; inertia 30.6 kg·cm²; pole pairs 21 | Parameter-table values; load-rating test methods are not disclosed. | M · Manufacturer claimed | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
| Independent exact-actuator robot validationindependent_robot_validation | Not published in cited public evidence | RCI checked the cited official public evidence on the verification date.RCI has not received, serialised, loaded, thermally instrumented or endurance-tested an RMD-X8-P9-25-C-N. | U · Unknown | MYACTUATOR X8-25-V2-en technical-parameter image ↗Product-parameters table, installation drawing and rated-torque test-method note embedded as an image on the V2-X8-25 details page · Image file X8-25-V2-en.jpg served from the official details page, observed 2026-08-18 Checked 2026-08-19 |
Known limits
What this record does not prove.
- The task-relevant marketing name “RMD-X8 Pro” is a previous name; the official site currently lists this actuator only as V2-X8-25 with single encoder, and no V3 X8 Pro details page exists on myactuator.com as of the verification date.
- The technical-parameter table is image-based (X8-25-V2-en.jpg) and shows no document revision number.
- Peak torque and peak current are endpoints; only the rated 10 N·m point carries the published thermal-balance definition.
- No serialised specimen, RCI torque test or thermal test exists for this record.